Impact Factor
7.883
Call For Paper
Volume 12 Issue 10
October 2026
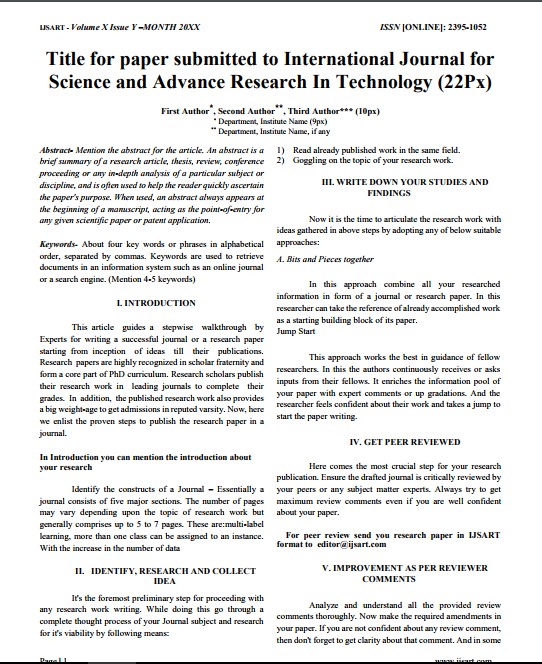
Download Paper Format
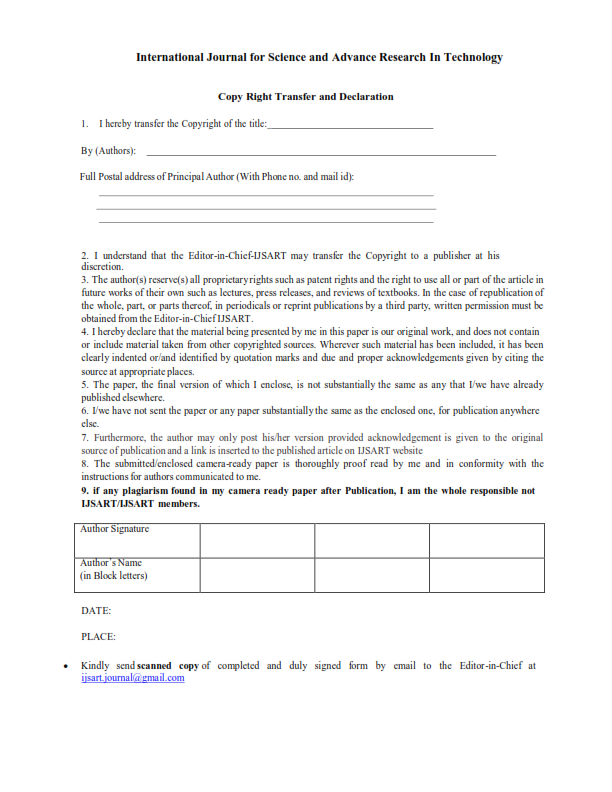
Copyright Form

Author(s)
Soundari Rebekha A
Abstract
Object Recognition In Unseen Indoor Environments Remains A Challenging Problem For Visual Perception Of Mobile Robots. In This Letter, We Propose The Use Of Topologically Persistent Features, Which Rely On The Objects’ Shape Infor- Mation, To Address This
Keywords
Paper ID
IJSARTV8I856755
Publication Date
August 26, 2022